
J-Tech · 3-axis machining
J-Tech JT-TL510A
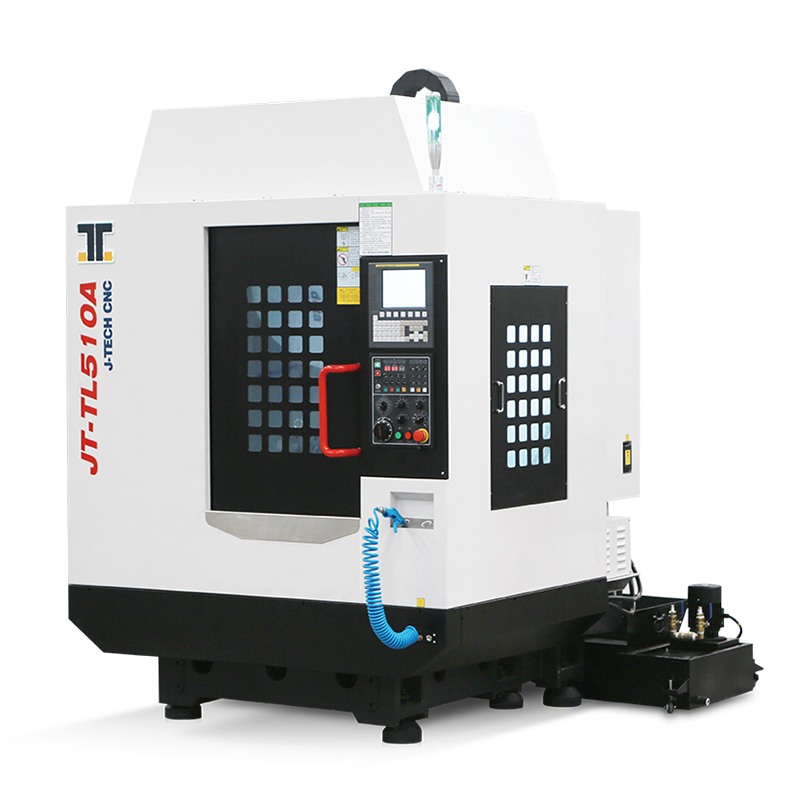
JT-TL510A is J-TECH’s compact BT30 drilling and tapping centre reference for supported housings and small parts. Its exact table lists 510 × 400 × 350 mm travel, a 650 × 400 mm table and 250 kg load reference. Include the fixture and its offset rather than checking only the blank. For a thin shell, identify support points and clamping forces, then inspect critical form and datum relationships after release where deformation matters.
The model table gives 150–500 mm spindle-nose-to-table distance and 450 mm spindle-centre-to-column distance. Draw the shortest tool at the lowest feature and the longest holder above the tallest clamp. Its 20,000 rpm direct spindle uses BT30. Obtain duty and torque at the actual tap/cutter speeds; maximum rpm does not establish useful low-speed torque or tool life. The 60 m/min rapid reference is distinct from the listed 1–10,000 mm/min cutting-feed range and full-part cycle.
The exact table gives 21 magazine positions, Ø60/80 mm maximum tool diameter and 200 mm length, but the structure caption labels 16 tools. The diameter pair does not define occupied-neighbour conditions. Request the selected magazine, complete-holder mass and occupied-tool map. The headline describes 1.9 s tool-to-tool whereas the table gives 2 s without the same definition. Keep those references separate and include approach, tapping reversal, chip clearing and inspection in elapsed time.
Catalog specifications
- X / Y / Z travel
- 510 / 400 / 350 mm
- Table size / load
- 650 × 400 mm / 250 kg
- Spindle nose to table
- 150–500 mm
- Spindle centre to column
- 450 mm
- Model-table spindle
- 20,000 rpm direct / BT30
- Rapid X / Y / Z
- 60 / 60 / 60 m/min
The table names FANUC 0i-MF and lists a 1840 × 2290 × 2645 mm machine body at 2800 kg, with three-phase 380 V/50 Hz/12 kVA supply. Obtain delivered layout, utilities and access separately. Trial the deepest blind thread, burr-sensitive edge and released housing using the actual fixture and thermal conditions. The manufacturer describes robot loading and inspection integration, but those require separate interfaces, safeguards, sorting and combined-cell acceptance. The original photograph is visibly marked JT-TL510A and is retained whole.